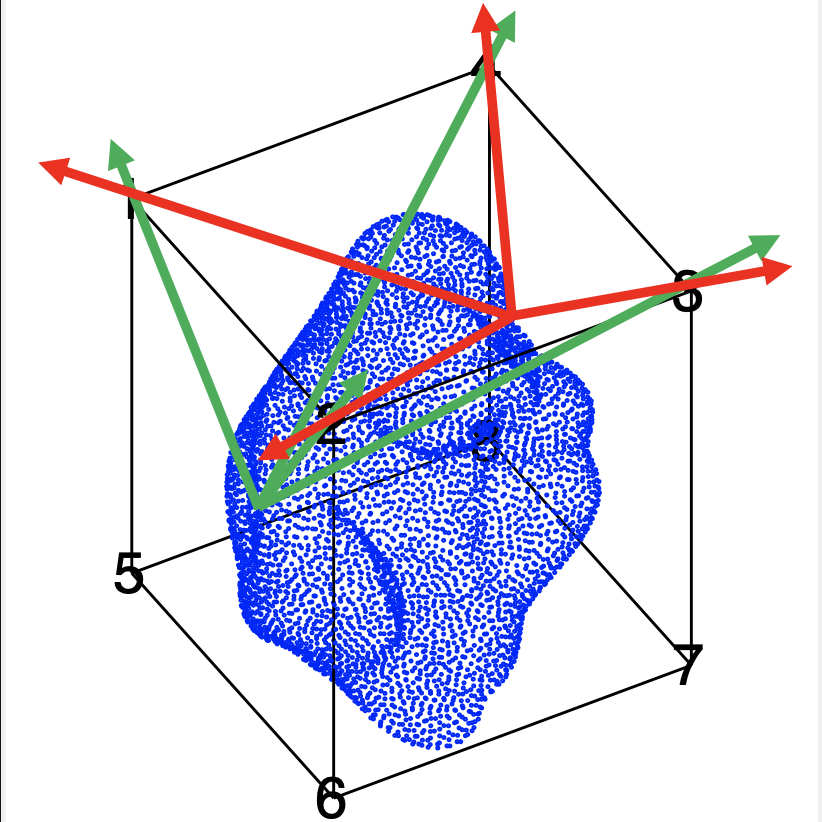
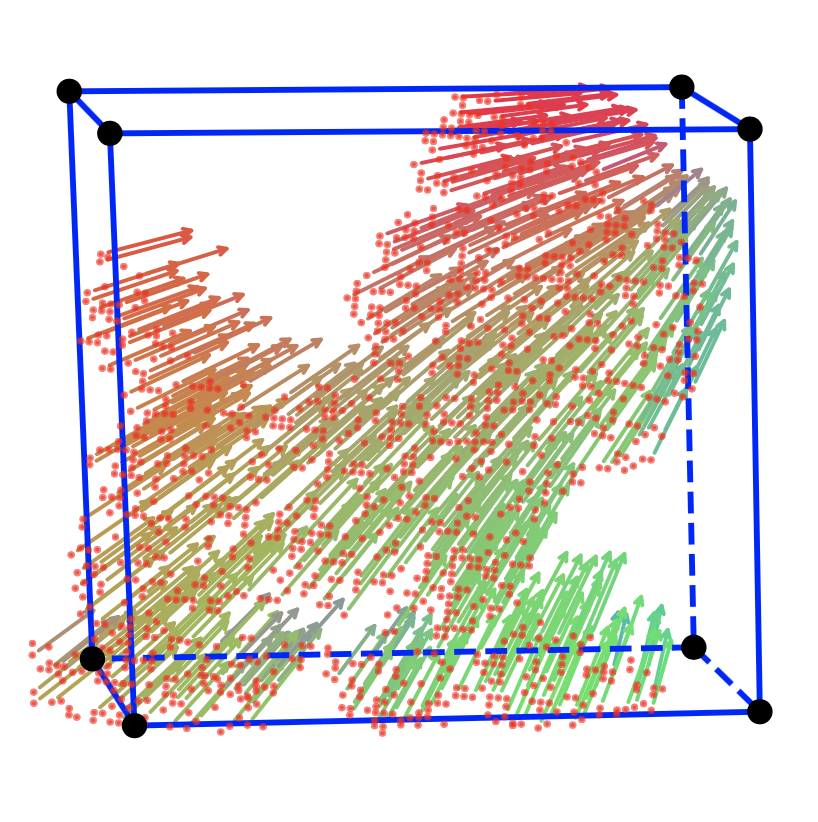
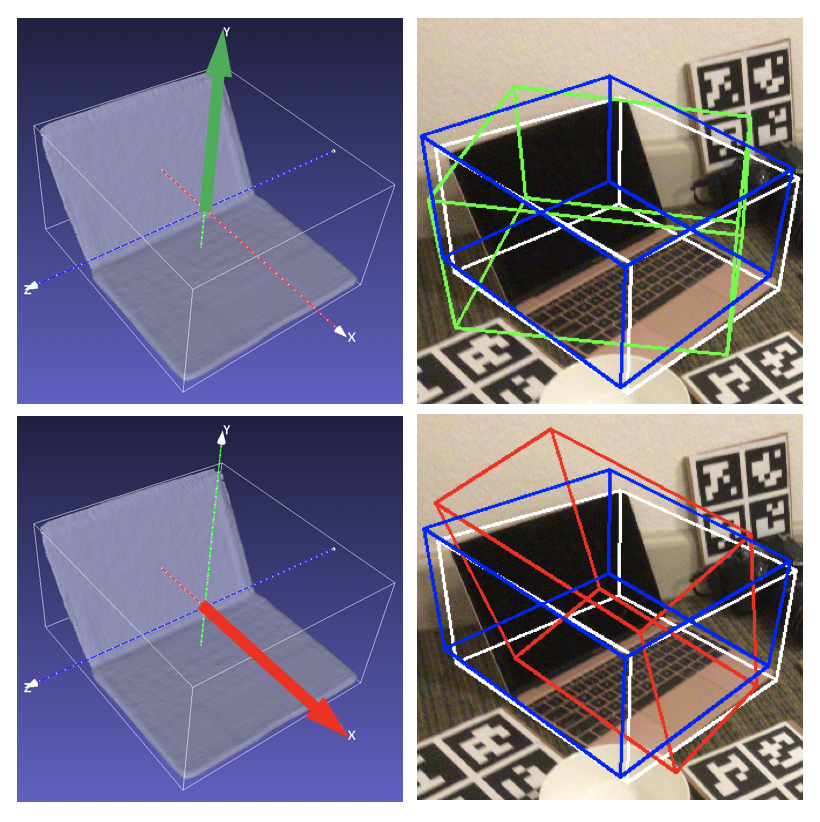
Instance-level pose 1 Point-wise voting with RANSAC for robust 6D pose estimation. This work is published in WACV 2020. 2 Embedding vector feature for real-time 6D pose estimation. This work is published in CVPR 2020. Category-level pose 1 Decoupled rotation representation for category-level 6D pose estimation. This work is published in CVPR 2021.